

SHANGHAI -- (BUSINESS WIRE) --
Robbyant, an embodied AI company within Ant Group, today announced the open-source release of LingBot-Touch, a tactile foundation model that gives robots a critical missing sense by enabling robust touch perception.
This press release features multimedia. View the full release here: https://www.businesswire.com/news/home/20261109284905/en/
Pre-trained on nearly 5,000 hours of real-world tactile data, the model covers three mainstream sensing modalities—magnetic tactile, visual tactile, and piezoresistive sensing—and translates their diverse signals into a unified tactile representation. This allows different dexterous hands and action models to share and reuse tactile understanding, enabling robots to not only “see clearer” and “think deeper,” but also “feel sharper” during fine manipulation tasks, such as turning pages, unscrewing bottle caps, and identifying Mahjong tiles.
A Unified Tactile Representation Across Sensors and Hands
Equipping robots with tactile sensors does not automatically give them useful touch perception. Commercial tactile sensors are still in an early stage of development, with visual tactile, magnetic tactile, and piezoresistive approaches each carrying distinct advantages and limitations. Given differing cost structures and application scenarios, multiple technical routes are likely to coexist for the foreseeable future.
A more fundamental challenge lies in data compatibility. The same physical contact can produce different raw signals depending on sensing principles and contact-point layouts. If a model learns to interpret only one type of sensor, its tactile experience may become difficult to reuse when the sensor or dexterous hand changes, forcing teams to re-collect data, retrain models, and re-adapt their systems. Amid rapid hardware iteration, this tight coupling creates repeated development work and raises integration costs for hardware vendors, robot integrators, and model developers.
For tactile perception to scale, robots must move beyond dependence on specific sensor signals. Data from different sources should be trainable together, and accumulated tactile capabilities should be reusable across sensors, dexterous hands, models, and tasks.
LingBot-Touch addresses this challenge through a unified architecture. It provides separate encoding pathways for different sensing principles, processes heterogeneous raw signals, and maps contact points from different layouts into a shared fingertip coordinate space. A shared model then learns contact location, force distribution, and their temporal evolution, producing unified tactile tokens.
This design enables data collected from humans wearing tactile gloves and from teleoperated dexterous hands to be jointly used for training. Different action models can also leverage the trained model to extract contact features. The architecture is also designed to accommodate new types of tactile sensors as they emerge.
Significant Gains in Real-World Dexterous Manipulation
To evaluate how tactile representation improves real robot performance, Robbyant conducted 26 real-world tests across two dexterous hands, Sharpa Wave and XHand. After integrating LingBot-Touch, four action models—LingBot-VLA, π0.5, Diffusion Policy, and T-Rex—achieved average task success rate improvements of approximately 14 to 26 percentage points compared with operating without tactile input.
In one representative test using T-Rex to control Sharpa Wave for unscrewing a bottle cap, the success rate was 56.25% without tactile input and 62.5% when raw sensor signals were directly fed into the policy. With LingBot-Touch’s tactile representation, the success rate rose to 90%.
On XHand, Robbyant’s team further validated cross-hardware reusability. The magnetic tactile sensor used on XHand was not included in LingBot-Touch’s pre-training data; all magnetic tactile experience came from human glove-collected data. To evaluate this reusability, the team kept LingBot-Touch’s parameters unchanged and trained only the action model using XHand demonstration data.
Flexible Model Sizes and Open-Source Availability
To balance perception capability with on-device compute constraints, Robbyant offers two model sizes. All 26 real-world tests were completed using the lightweight version, LingBot-Touch-Tiny, which contains approximately 5.3 million parameters. When integrated with LingBot-VLA, π0.5, and T-Rex, it adds only about 0.13% to 0.16% to total model size.
The larger-capacity version shows further potential in perception tests. As pre-training data approaches 5,000 hours, the model continues to benefit from additional data, indicating that tactile pre-training still has substantial room for scaling and improvement.
LingBot-Touch was evaluated across four different action models and is not tied to Robbyant’s proprietary models. It serves as a general-purpose perception layer between tactile sensors and action models, rather than a dedicated module built for a specific hardware platform or control policy. With LingBot-Touch, sensor and dexterous-hand manufacturers can select hardware based on cost and task requirements, while robotics teams can retain their own action policies. This significantly reduces the need to rebuild tactile capabilities each time a new hardware–algorithm combination is adopted.
LingBot-Touch's technical report and code are now open source. Developers can access and download the model on Hugging Face and GitHub.
Robbyant's unified robot brain already covers high-precision spatial perception, high-dynamic environment interaction, and generalizable dexterous manipulation, helping robots see clearer, think deeper, and act faster. With LingBot-Touch now integrated into LingBot-VLA, the robot brain's perception extends to the fingertips, enabling robots to "feel sharper" and further advancing Robbyant's general-purpose embodied intelligence.
About Robbyant
Robbyant is an embodied intelligence company within Ant Group, dedicated to advancing embodied intelligence through cutting-edge software and hardware technologies. Robbyant independently develops foundational large models for embodied AI and actively explores next-generation intelligent devices, aiming to create robotic companions and caregivers that truly understand and enhance people’s everyday lives and deliver reliable intelligent services across key use cases, such as elderly care, medical assistance, and household tasks.
To learn more about Robbyant, please visit: www.robbyant.com
View source version on businesswire.com: https://www.businesswire.com/news/home/20261109284905/en/
CONTACT:
Media Inquires
Vick Li Wei
Ant Group
Vick.lw@antgroup.com
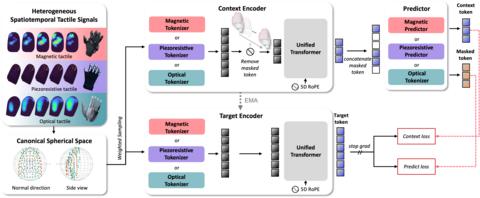
LingBot-Touch encodes magnetic tactile, visual tactile, and piezoresistive signals into unified tactile tokens for use by different action models.